SOFT ROBOTICS · TACTILE SENSING · ROBOT MANIPULATION
Tactile sensing and compliant robotic systems
My research examines how tactile sensing and mechanical compliance contribute to robot perception and manipulation. I develop and experimentally characterize soft sensors, robotic mechanisms, and systems for contact-rich interaction.

RESEARCH AREAS
Research interests
My work investigates the relationship between robot morphology, sensory feedback, and physical interaction with objects and environments.
Tactile and distributed sensing
Development and characterization of optical and embedded tactile sensors for estimating contact forces, moments, and deformation.
Compliant robotic mechanisms
Investigation of compliant actuators, variable-stiffness structures, and reconfigurable mechanisms for robotic manipulation.
Robot manipulation
Integration of physical compliance, tactile feedback, and learning-based control for grasping and tasks involving sustained contact.
SELECTED RESEARCH
Selected research projects
Representative studies in tactile sensing, compliant mechanisms, and contact-rich robotic manipulation.
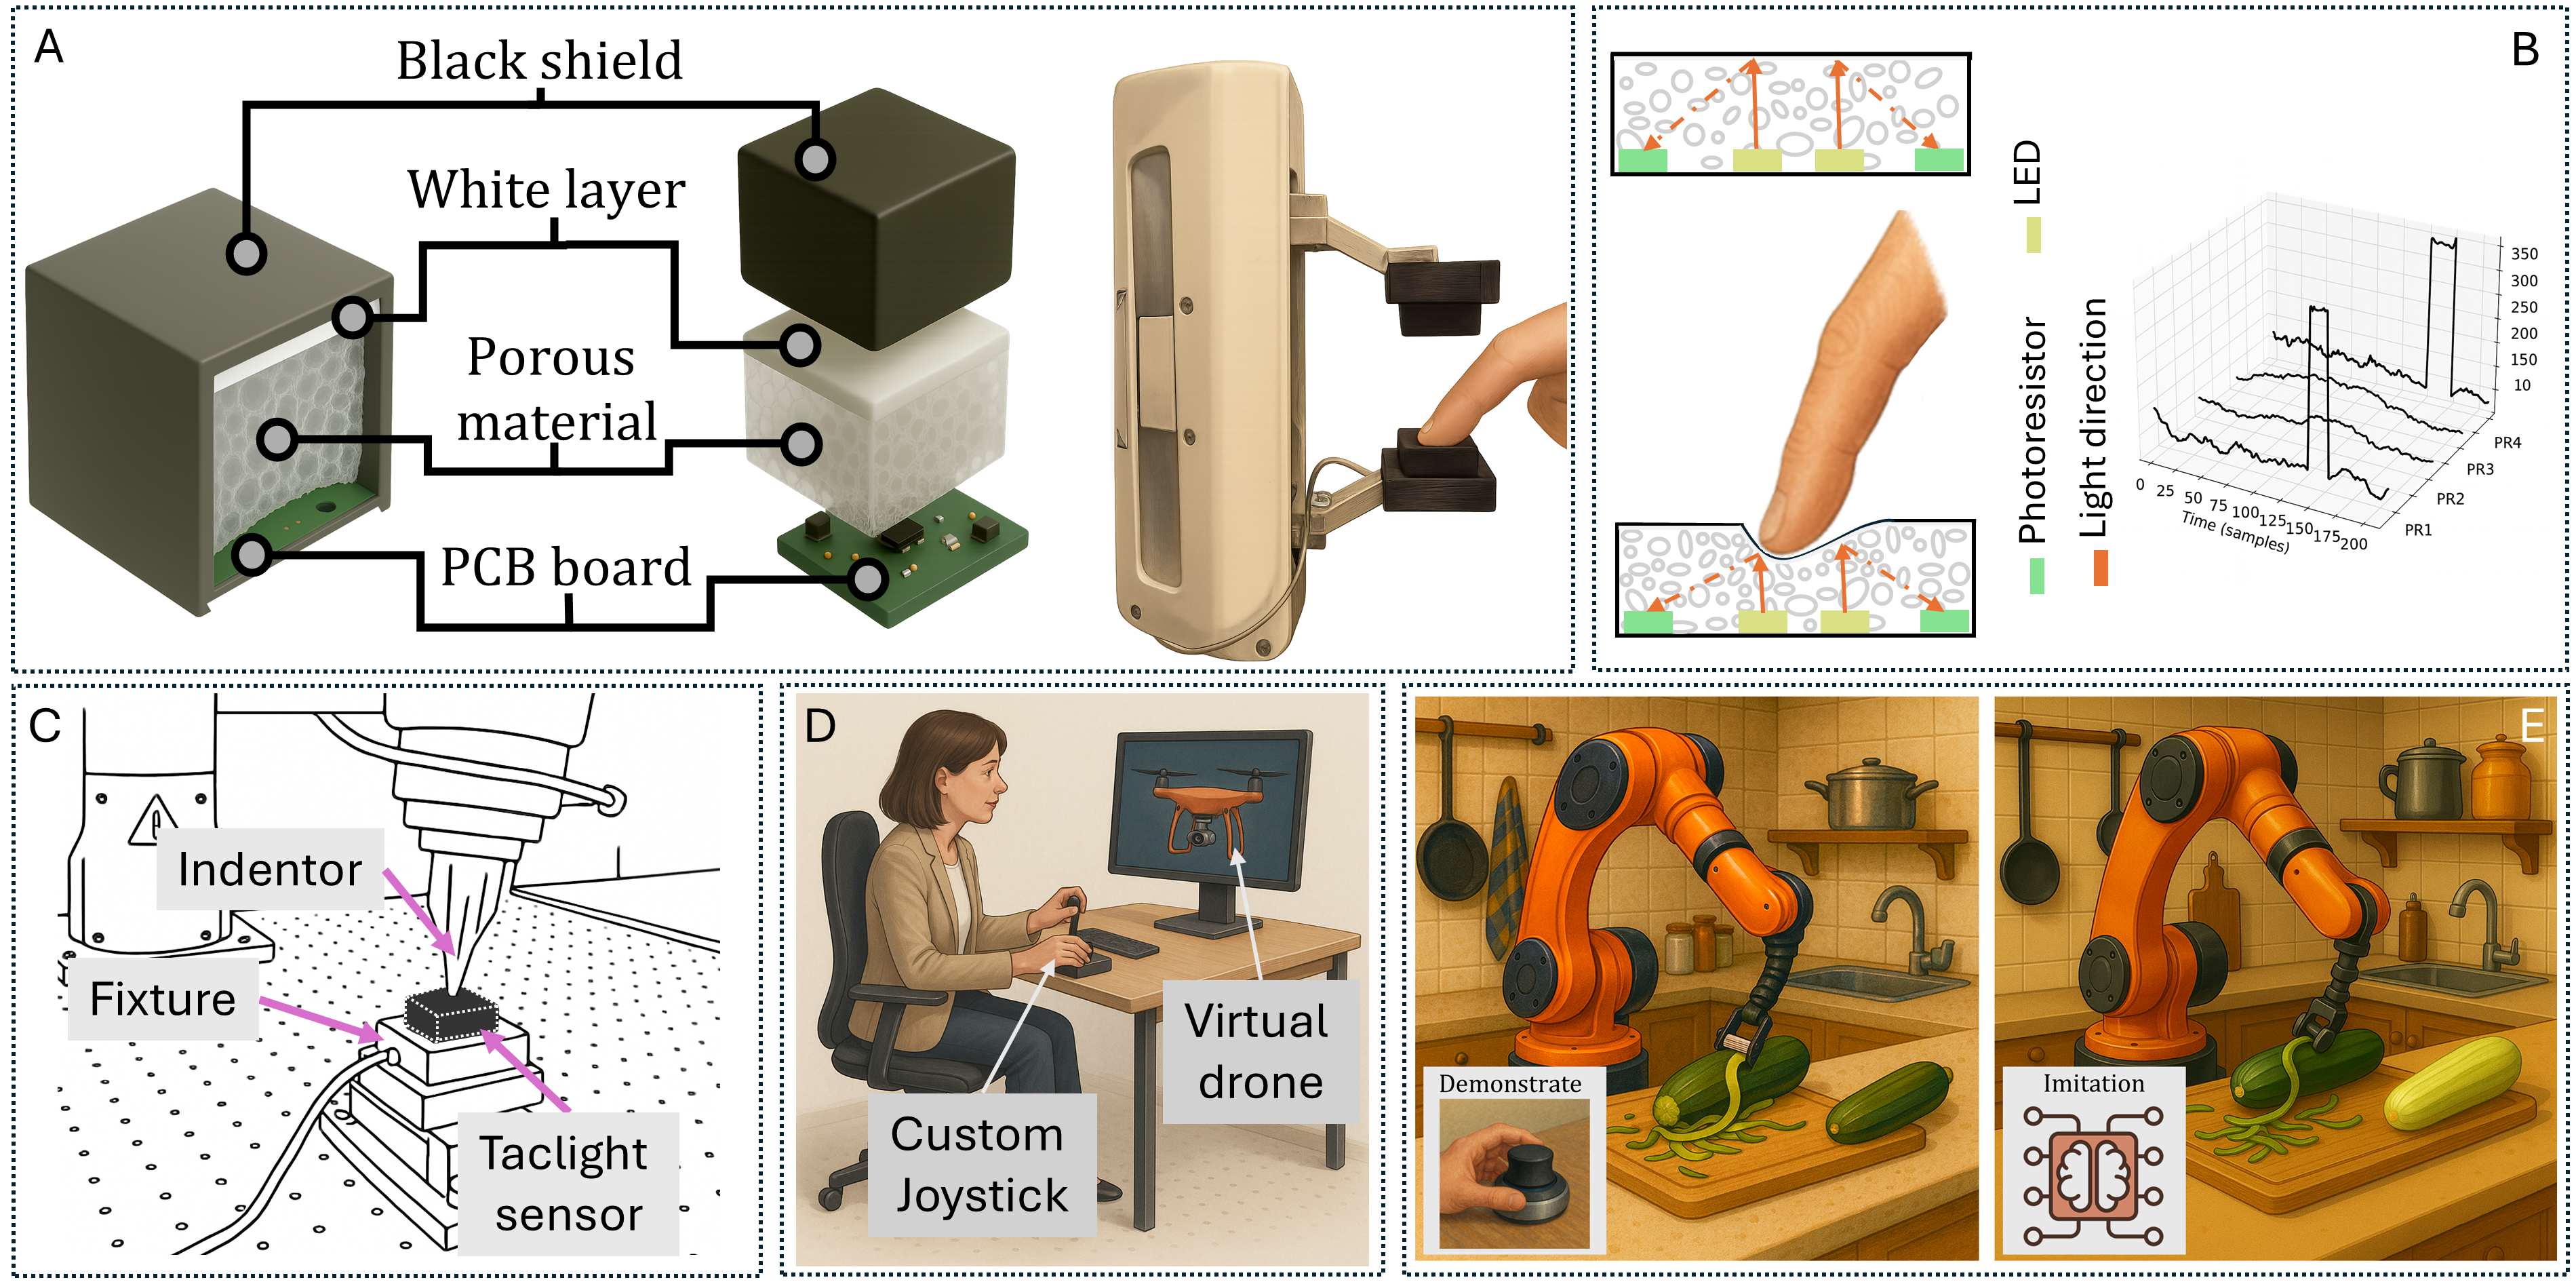
TACTILE SENSING
TacLight: optical tactile sensing
Development and characterization of a compact, camera-free sensor for six-axis force and moment estimation.
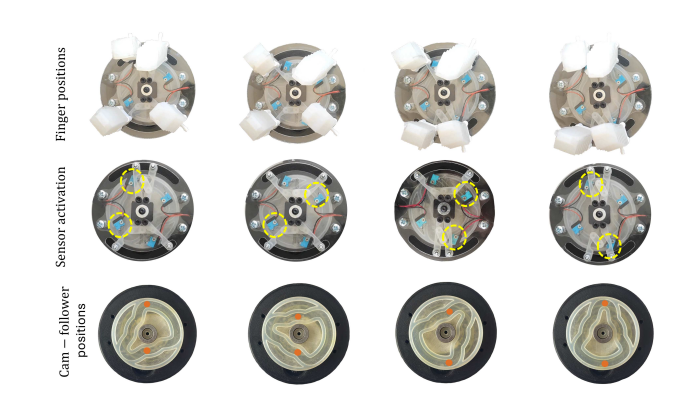
ROBOTIC MECHANISMS
ReconfiGrip: adaptive grasping
A cam-encoded, single-actuator mechanism for changing between two-, three-, and four-finger grasping configurations.
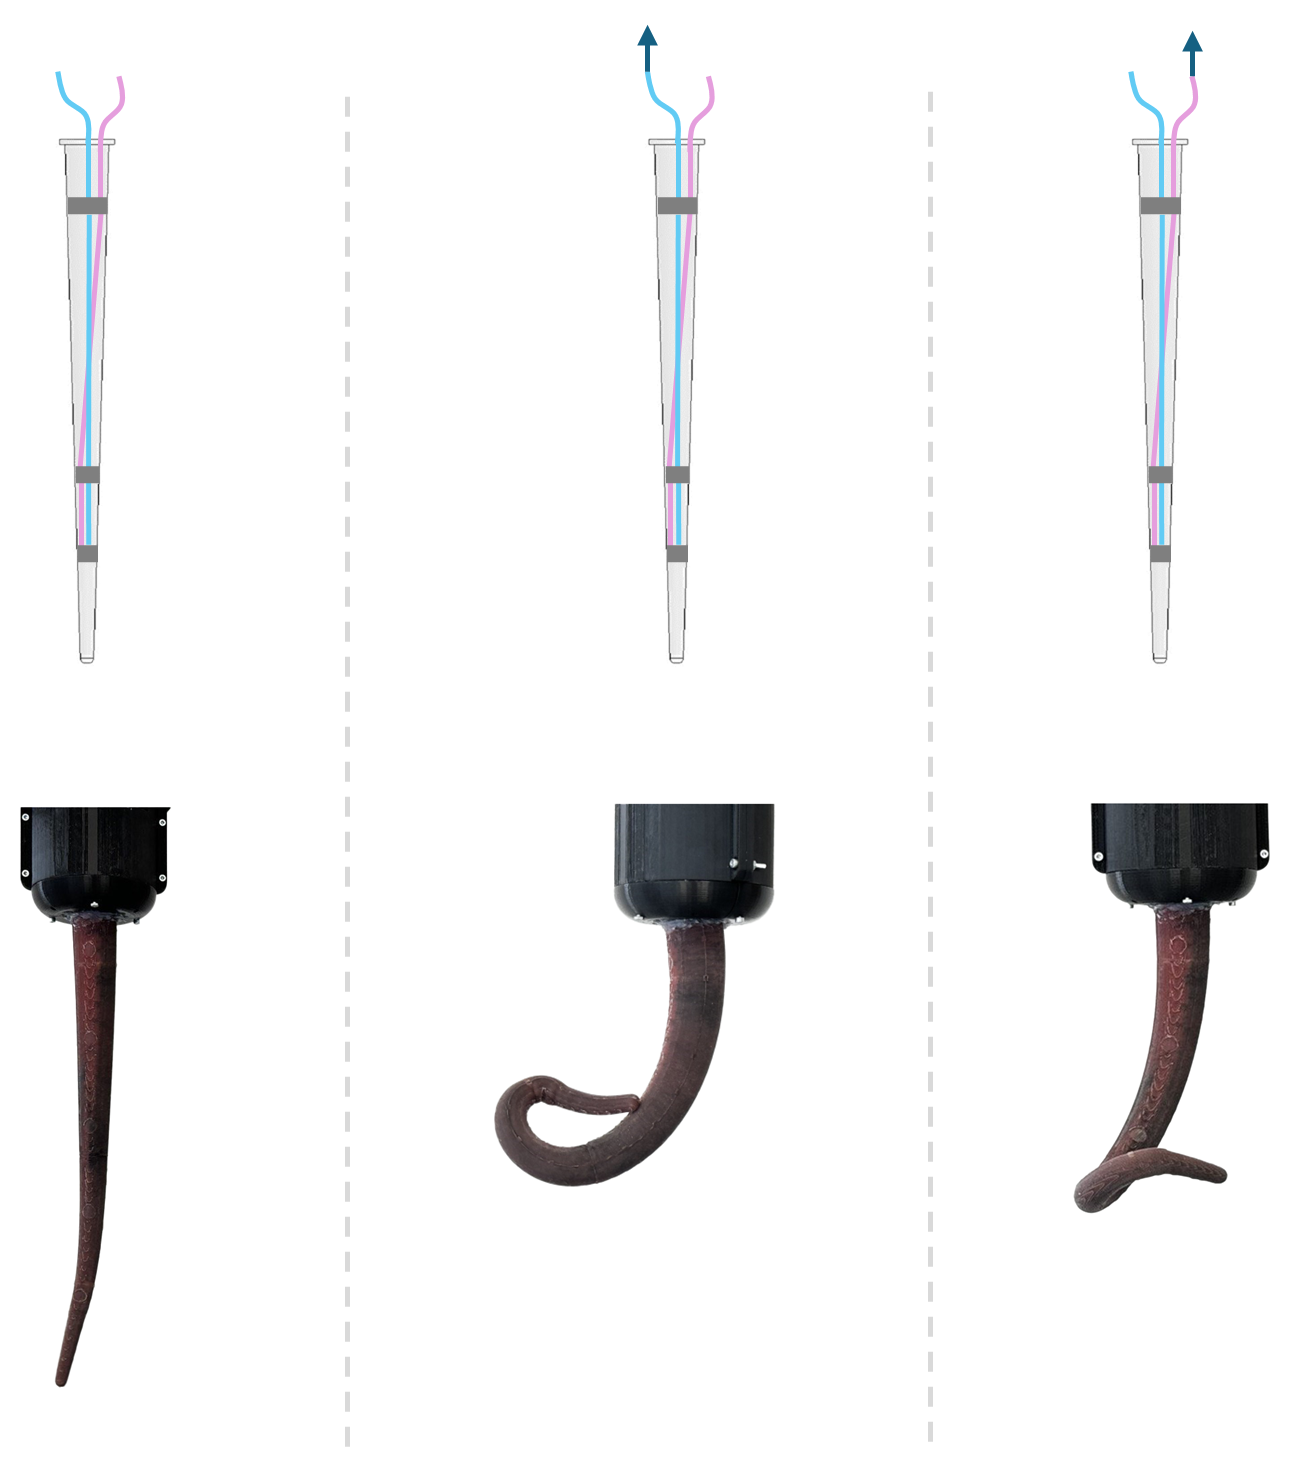
CONTACT-RICH MANIPULATION
Hybrid soft–rigid manipulation
Experimental investigation of a rigid manipulator coupled to a compliant robotic arm for contact-rich tasks.
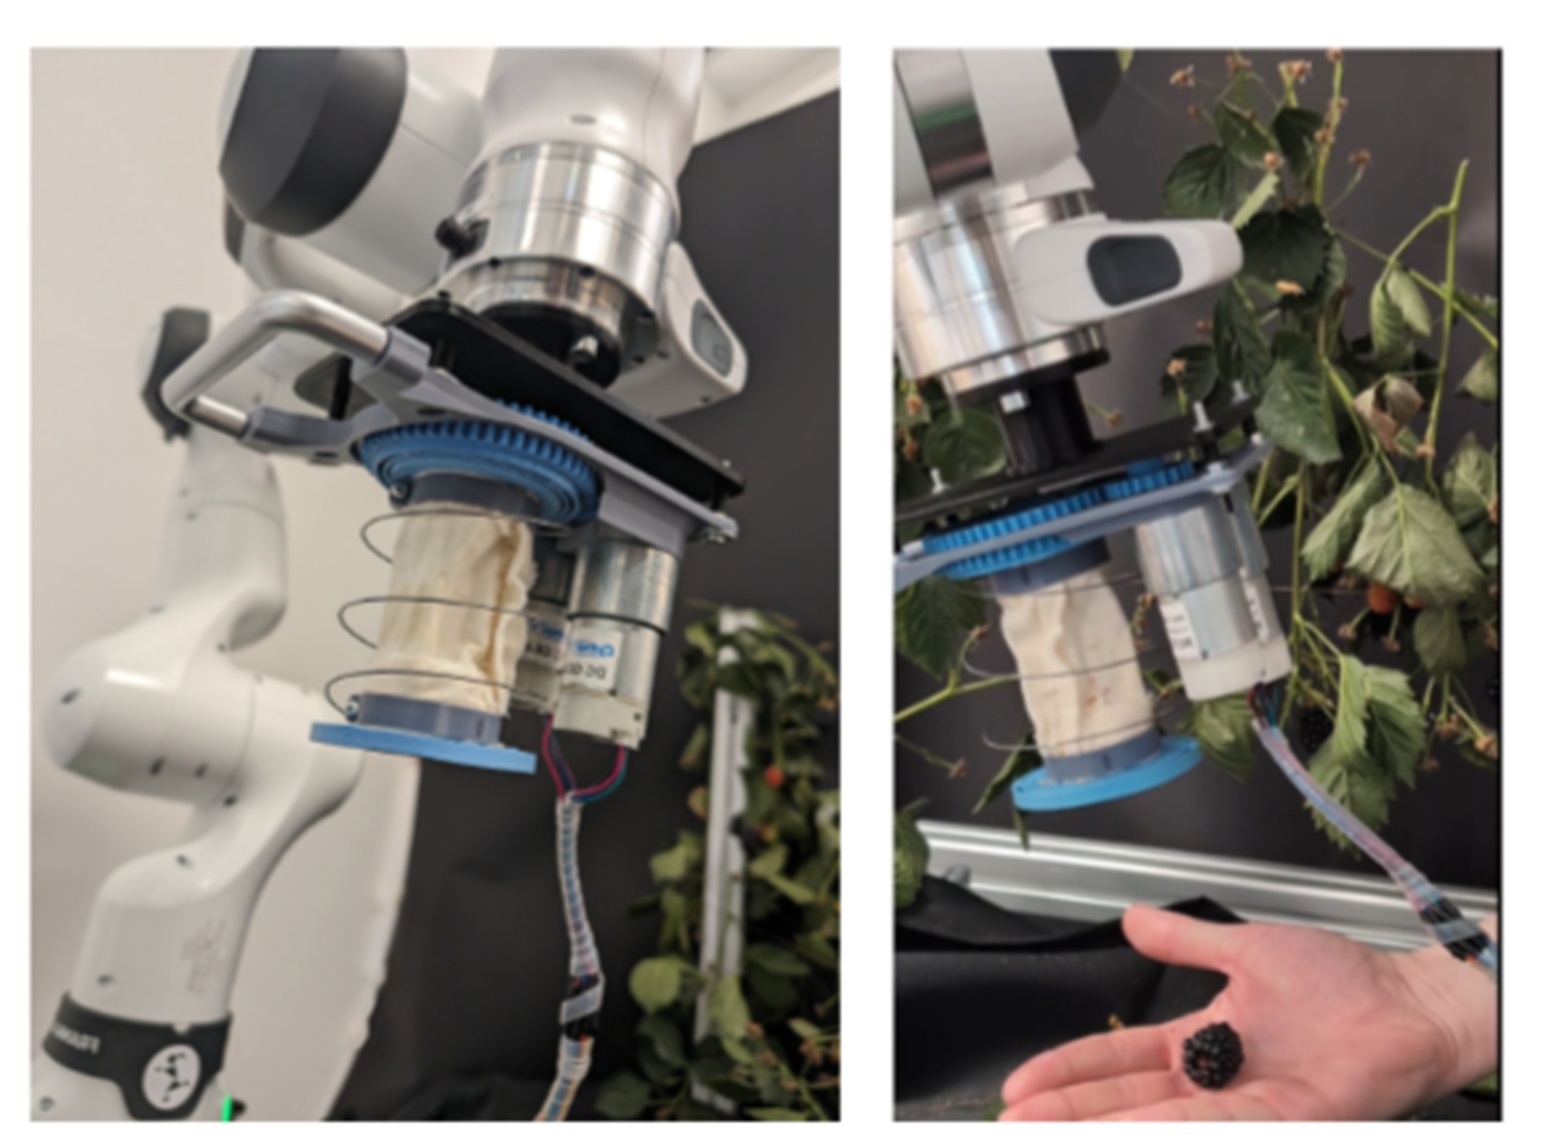
ROBOTIC HARVESTING
BerryTwist
Design and experimental evaluation of a twisting-tube soft gripper for blackberry grasping and detachment.
PUBLICATIONS
Selected publications
2026 · Nature Communications (Accepted)
Mastering Contact-rich Tasks by Combining Soft and Rigid Robotics with Imitation Learning
M. Ramírez Montero, E. Shahabi, G. Franzese, J. Kober, B. Mazzolai, and C. Della Santina
2026 · Nature Machine Intelligence
Peripheral control enabled by distributed sensing in an octopus-inspired soft robotic arm for autonomous underwater grasping
E. Del Dottore, R. Adhami, E. Shahabi, et al.
2026 · Research Square preprint
TacLight: A Six-Axis Soft Optical Tactile Sensor for Physical and Virtual Interaction
E. Shahabi, Z. Li, S. S. Baberwal, A. van der Kraan, V. Munoz, S. Coyle, J. Kober, and C. Della Santina
2024 · IEEE Robotics and Automation Letters
BerryTwist: a Twisting-Tube Soft Robotic Gripper for Blackberry Harvesting
J. F. Elfferich, E. Shahabi, C. Della Santina, and D. Dodou
2023 · Advanced Intelligent Systems
Octopus-Inspired Suction Cups with Embedded Strain Sensors for Object Recognition
E. Shahabi, F. Visentin, A. Mondini, and B. Mazzolai
ABOUT
Research background
I am a postdoctoral researcher at TU Delft investigating tactile sensing, soft robotic systems, and physical interaction.
My research combines mechanical design, embedded sensing, and experimental methods to study the role of morphology and tactile feedback in robotic manipulation.
Previous experience
Before my doctoral research, I spent seven years in industry and two years as a researcher at the National Taiwan University of Science and Technology. This experience continues to shape my approach to building and testing robotic systems.
My doctoral research at Scuola Superiore Sant’Anna and IIT focused on bioinspired soft robotics.
Academic service
Co-organizer, 2nd Unconventional Robotics Symposium, TU Delft, 14–15 September 2026.
Guest Editor, Robotics (MDPI), special issue “Soft Robotic Actuation and Locomotion: The State of the Art.”
Program Committee member, Workshop on Awareness in Learning Agents (ALA), ECAI 2025, Bologna, Italy, 25 October 2025.
CONTACT
Contact and collaboration
For research collaborations, academic enquiries, and scientific exchange.

